
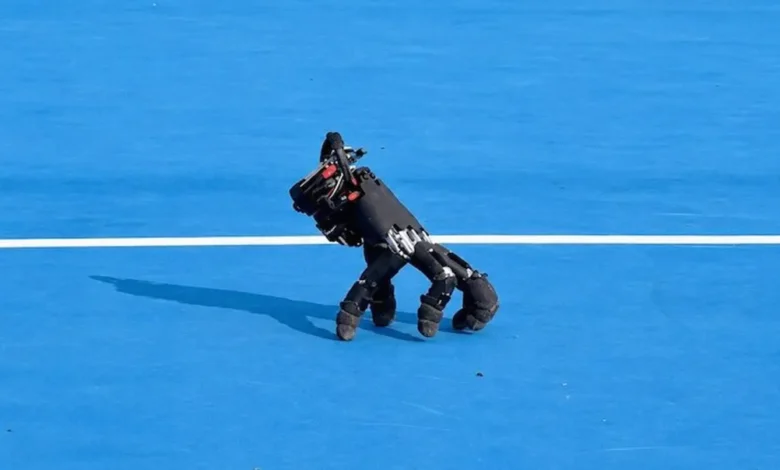
Rather than adding wheels or legs to the system, the team turns the hand itself into a mobile robot, allowing its fingers to alternate between supporting, moving and manipulating its body. The prototype is based on a commercially available anthropomorphic hand equipped with five fingers and 20 actuated joints, four for each finger. Researchers Amirhossein Kazemipour, Hehui Zheng and Robert K. Katzschmann added a compact onboard system containing a battery, sensors and computing hardware, bringing the complete untethered robot to 818 grams.
The resulting machine needs no external arm to carry it around and, despite looking suspiciously ready for a role in The Addams Family, is intended as a practical experiment in mobile manipulation. R E I N F O R C E M E N T LEARNING PUTS FIVE FINGERS TO WORK Teaching a hand to walk is slightly more complicated than asking it to behave like a very small quadruped. Unlike legs, its five fingers have different geometries and ranges of motion, while the palm naturally sits at an angle. When one finger leaves the ground to take a step or interact with something, the others must continue balancing the robot’s entire weight.
The researchers addressed this asymmetry through reinforcement learning, training locomotion policies in simulation before transferring them to the physical hand. The results take the robot well beyond a tabletop demonstration. ETH Zurich’s hand was able to move untethered across 14 indoor and outdoor surfaces, including carpet, tile, metal grating, asphalt, grass, gravel and weathered stone. When deliberately placed on its side, it successfully pushed itself back upright in 21 of 25 trials. Its fingers can also switch from locomotion to manipulation: in one experiment, the robot supported itself while pressing keyboard arrow keys, correctly hitting 29 out of 32 targets. It then put those keyboard skills to excellent use by completing moves in the puzzle game Sokoban.